Object Handling
Privacy reviewed
In QA
Object Sorting & Placement Dataset
Structured pick-sort-place sequences across varied object categories — recyclables, hardware, and mixed household items — useful for manipulation and grasping research.
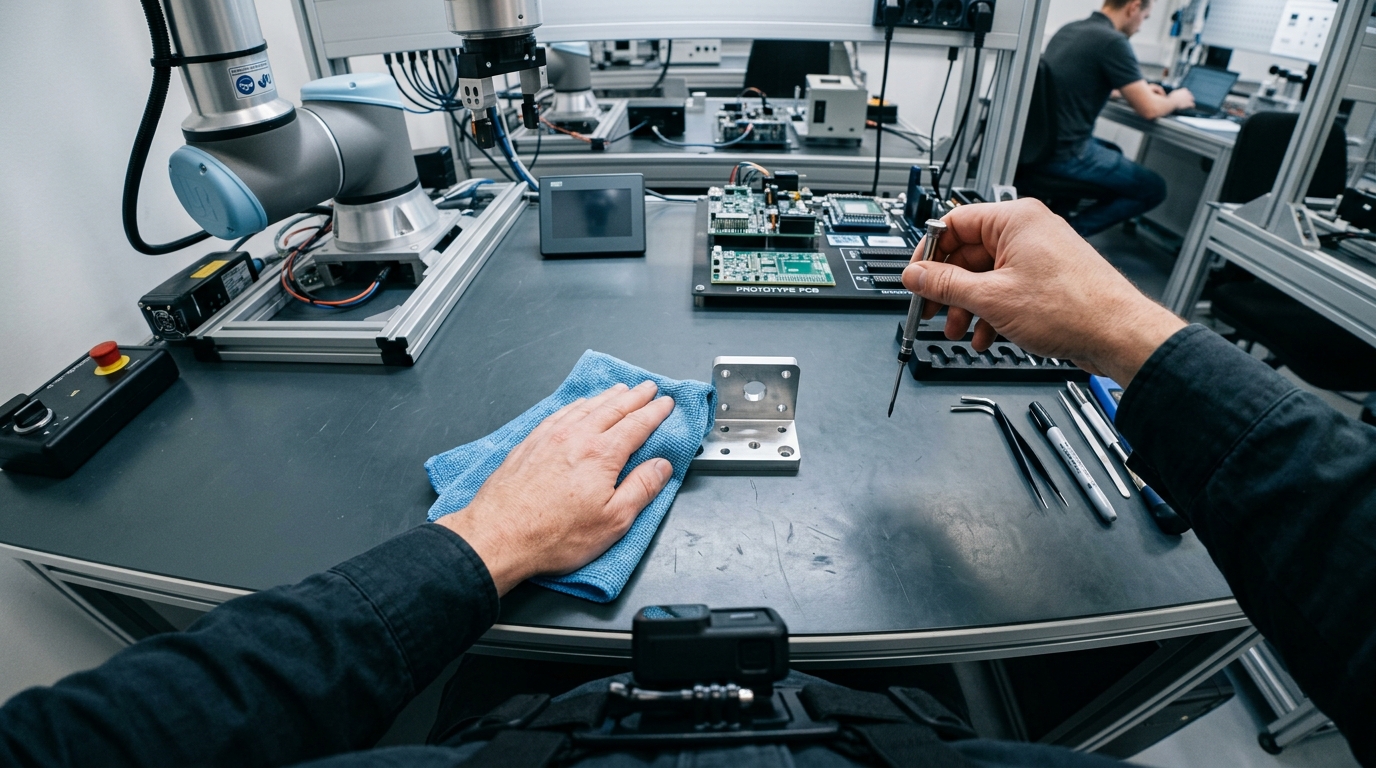
SPEC_ID // OBJECT-SORTING-PLACEMENT
4K / 60FPSCONSENT_VERIFIED
Clip count
71
71 clips in QA
Task families
5
4–6 task types
Capture Sites
2
Controlled environments
Consent Status
100%
Documented legal clearance
Environments
Site Layout Scenarios
- MOCK APARTMENT
- STORAGE ROOM
Camera perspectives
Grounded Camera Views
- STATIC CAMERA
- SMARTPHONE HANDHELD
- CHEST-MOUNTED PERSPECTIVE
- SYNCHRONIZED MULTI-VIEW
- RGB-D
Annotation schema
Derived Metadata Fields
- Task labels
- Object labels
- Grasp outcome
- Start / end timestamps
- Quality scores
- Privacy review status
Use cases
Downstream Capabilities
Manipulation research
Grasping benchmarks
Object handling robotics
Task understanding
Quality check
QA Review Checklist
- // Every clip is reviewed by a human QA reviewer against a nine-point checklist before inclusion.
- // Clips are scored A (excellent), B (usable), C (weak but usable), or rejected outright.
- // Only clips with resolved annotations and no open privacy risk enter a published dataset package.
Risk mitigation
Privacy Redaction Pipeline
- // Automated and human review flags faces, badges, screens, and location signals in every clip.
- // Flagged clips are routed to redaction before being cleared for annotation.
- // Metadata is stripped of device location and identifying fields prior to licensing.
Capture samples
Illustrative Clip Previews
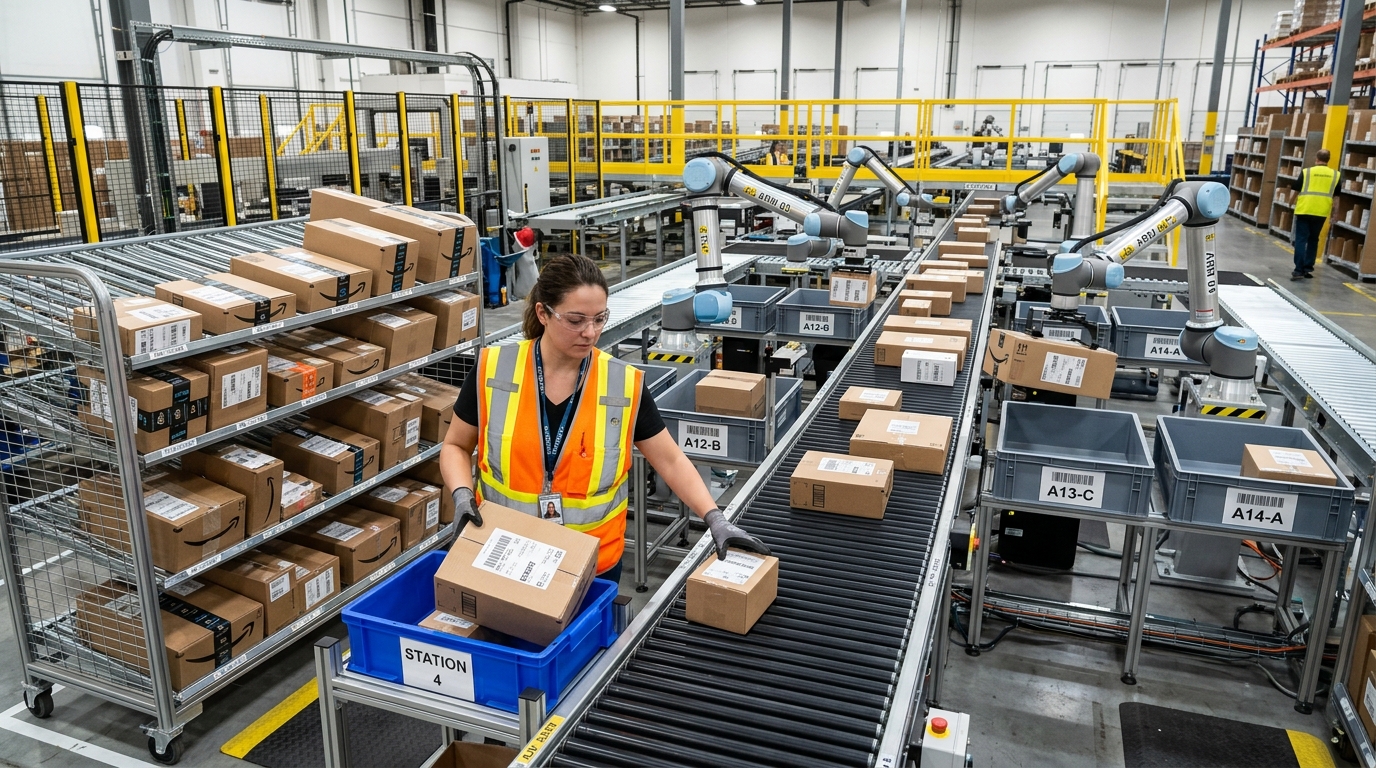
STREAM_01FRAME: #1042
RGB-D // 60FPSDURATION: 0:51
OSP-00008
Sort objects into containers
Mock Apartment
STREAM_02FRAME: #1226
RGB-D // 60FPSDURATION: 0:31
OSP-00015
Sort recyclables
Storage Room
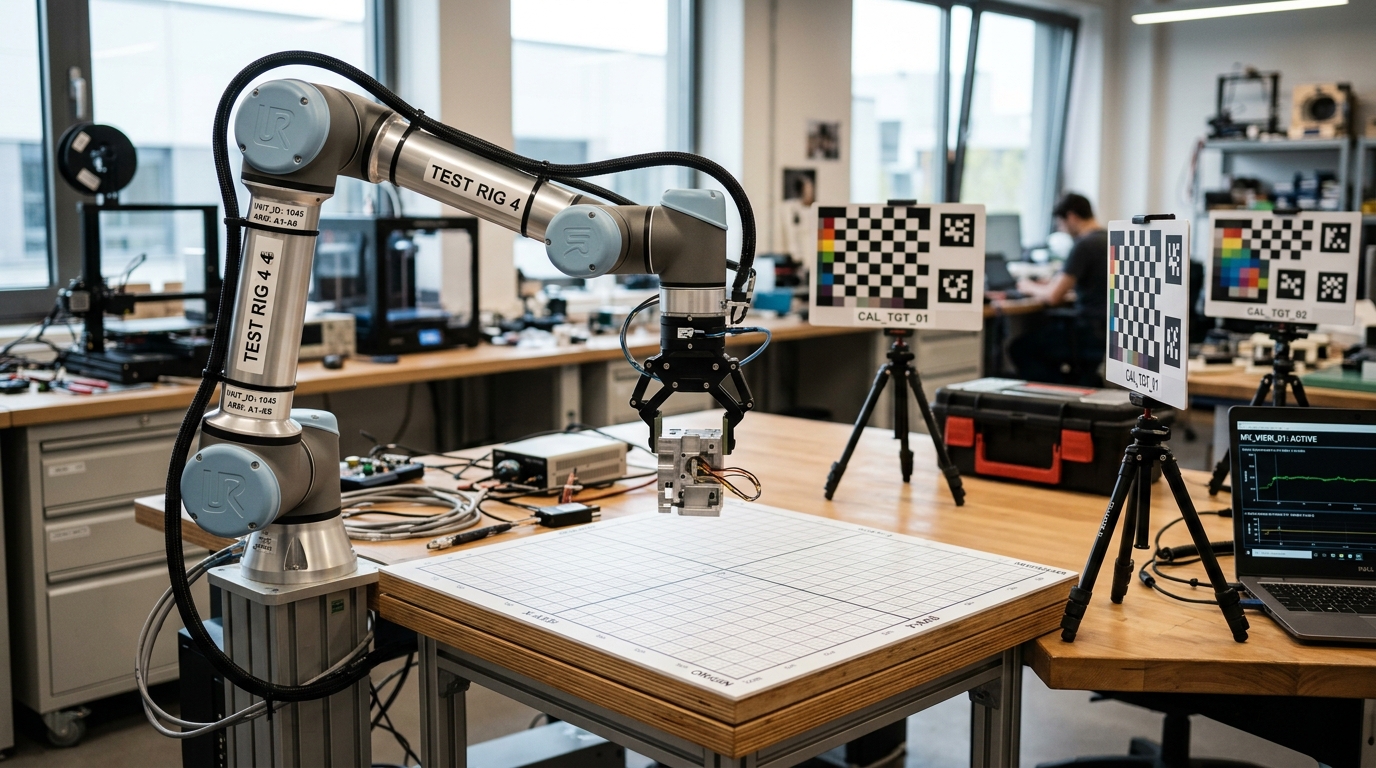
STREAM_03FRAME: #1410
RGB-D // 60FPSDURATION: 0:22
OSP-00022
Put objects into basket
Mock Apartment
Metadata payload
Sample Clip-Level Metadata
| Clip ID | Task | Site Environment | Duration | Outcome | Grade | Privacy Status |
|---|---|---|---|---|---|---|
| OSP-00008 | Sort objects into containers | Mock Apartment | 0:51 | Success | QA_B | Cleared |
| OSP-00015 | Sort recyclables | Storage Room | 0:31 | Success | QA_A | Cleared |
| OSP-00022 | Put objects into basket | Mock Apartment | 0:22 | Success | QA_A | Cleared |
Scope a Pilot dataset for: Object Sorting & Placement Dataset
We provide detailed annotation guides, sensor configurations, and custom data formats tailored to your Embodied AI platform.